Drone Stack
AUTONOMOUS FLIGHT PLATFORM
Flight controllers written from scratch, a companion computer that picks a person out of the video stream and follows them, and a ground station on the Play Store. Built up over three years and several airframes.
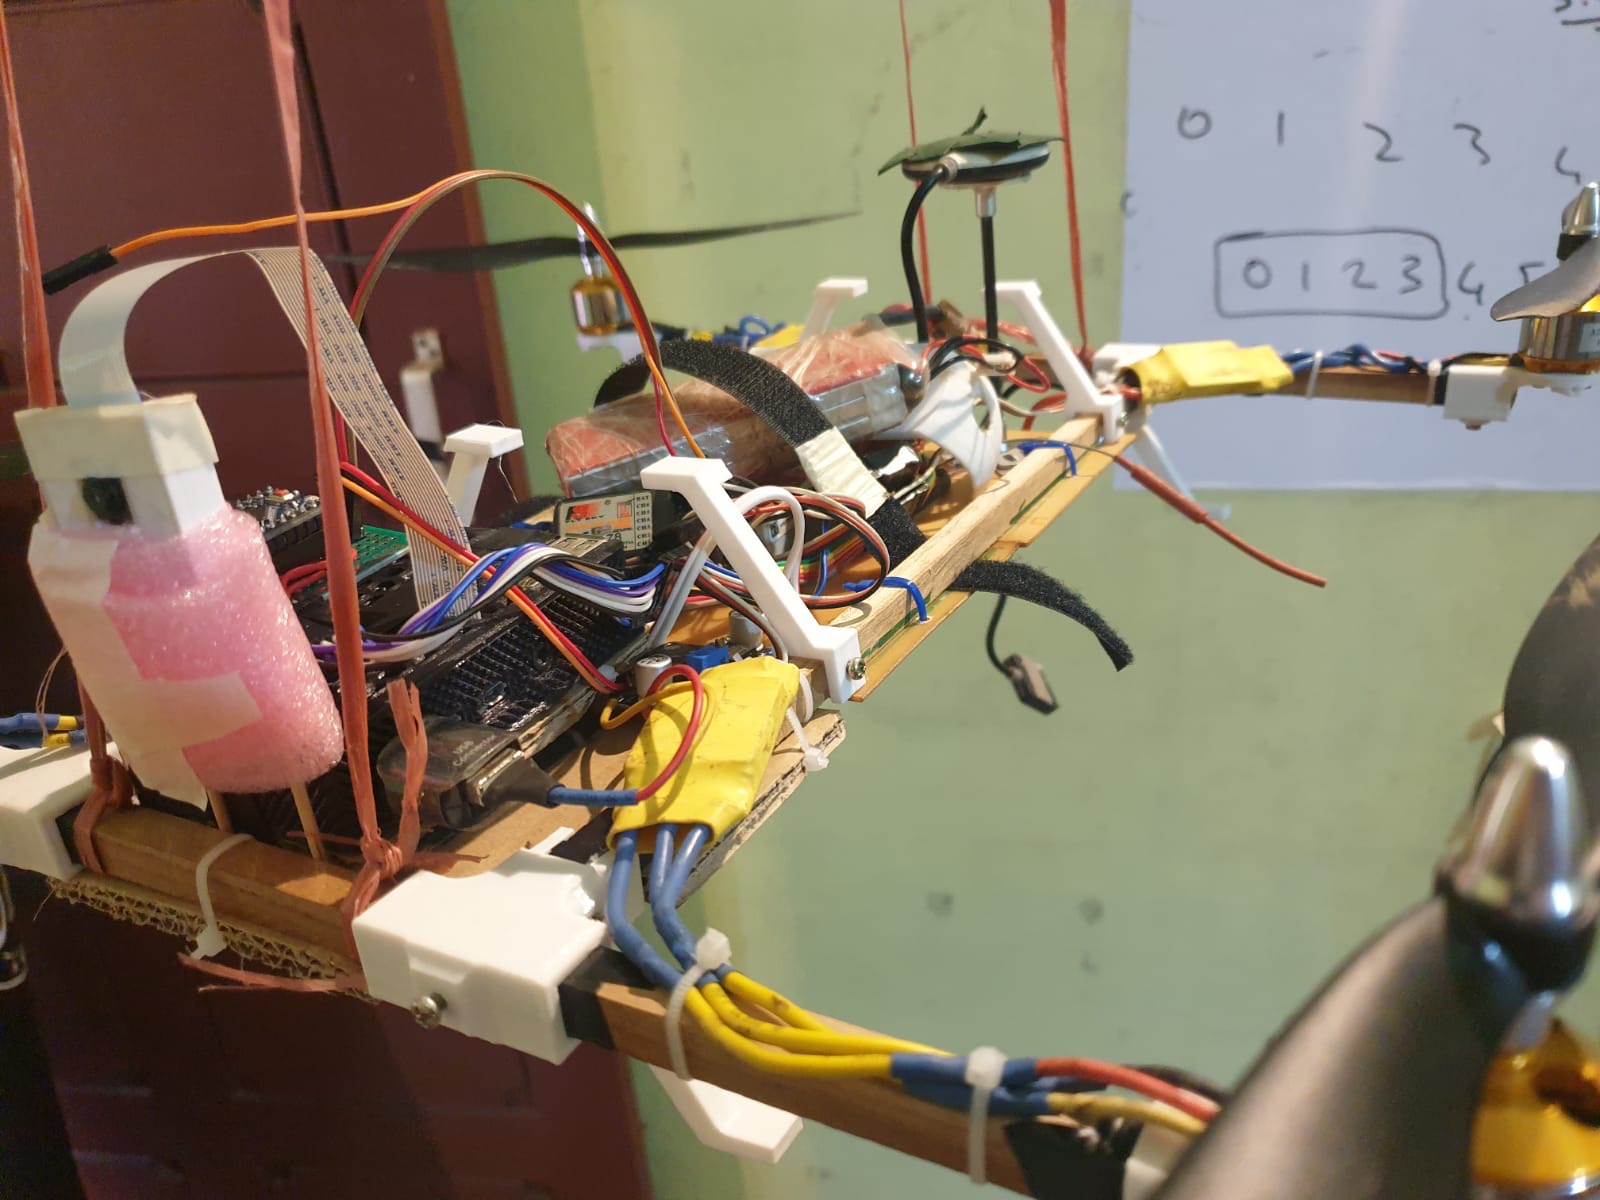
This is where all of it started, and it is still the clearest example of what I mean by the whole vertical: I wrote the control loop, the perception on top of it, the link between them, and the app in the operator’s hand.
The flight controller runs on an RP2040 — IMU fusion, PID loops and mixing, closing fast enough to keep a quad in the air. A second firmware targets ESP32 and is meant to fly several airframes from one codebase.
On top rides a Raspberry Pi doing OpenCV person tracking, feeding setpoints down to whatever commercial flight controller is underneath. The ground station is a Flutter app shipped on Google Play.
The airframes and mounts were modelled and printed, because at that scale nothing you can buy fits what you built.
COMPOSED OF
STACK, BY LAYER
- 01 PRODUCT Flutter ground station, shipped on Google Play
- 02 SERVICE —
- 03 DATA —
- 04 MODELS OpenCV person detection and tracking on the companion Pi
- 05 PROTOCOL MAVLink setpoints · WiFi telemetry link
- 06 FIRMWARE From-scratch flight controllers: IMU fusion, PID, mixing
- 07 SILICON RP2040 · ESP32 · Raspberry Pi · MPU6050 · printed airframes