Robotic Arm
SIX DEGREES OF FREEDOM
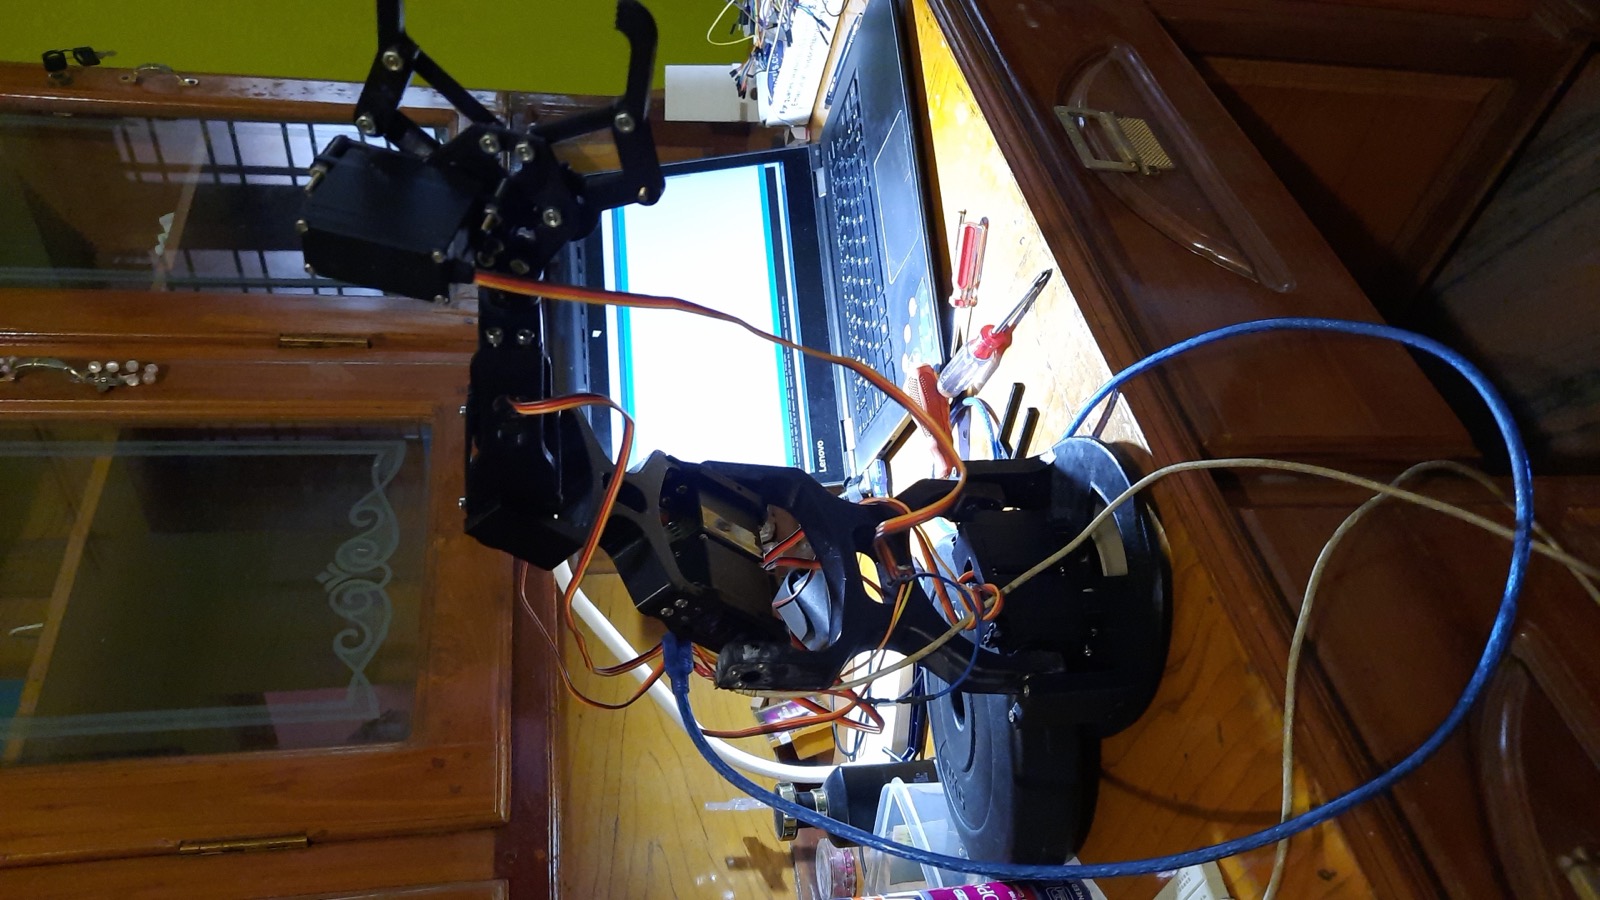
Driven either from a phone over WiFi or autonomously from a planned trajectory, with inverse kinematics solved on the microcontroller. Linkages modelled and printed to fit the servos I actually had.
ESP32Servo IKFlutterFusion 360FDM printing
NO REPO